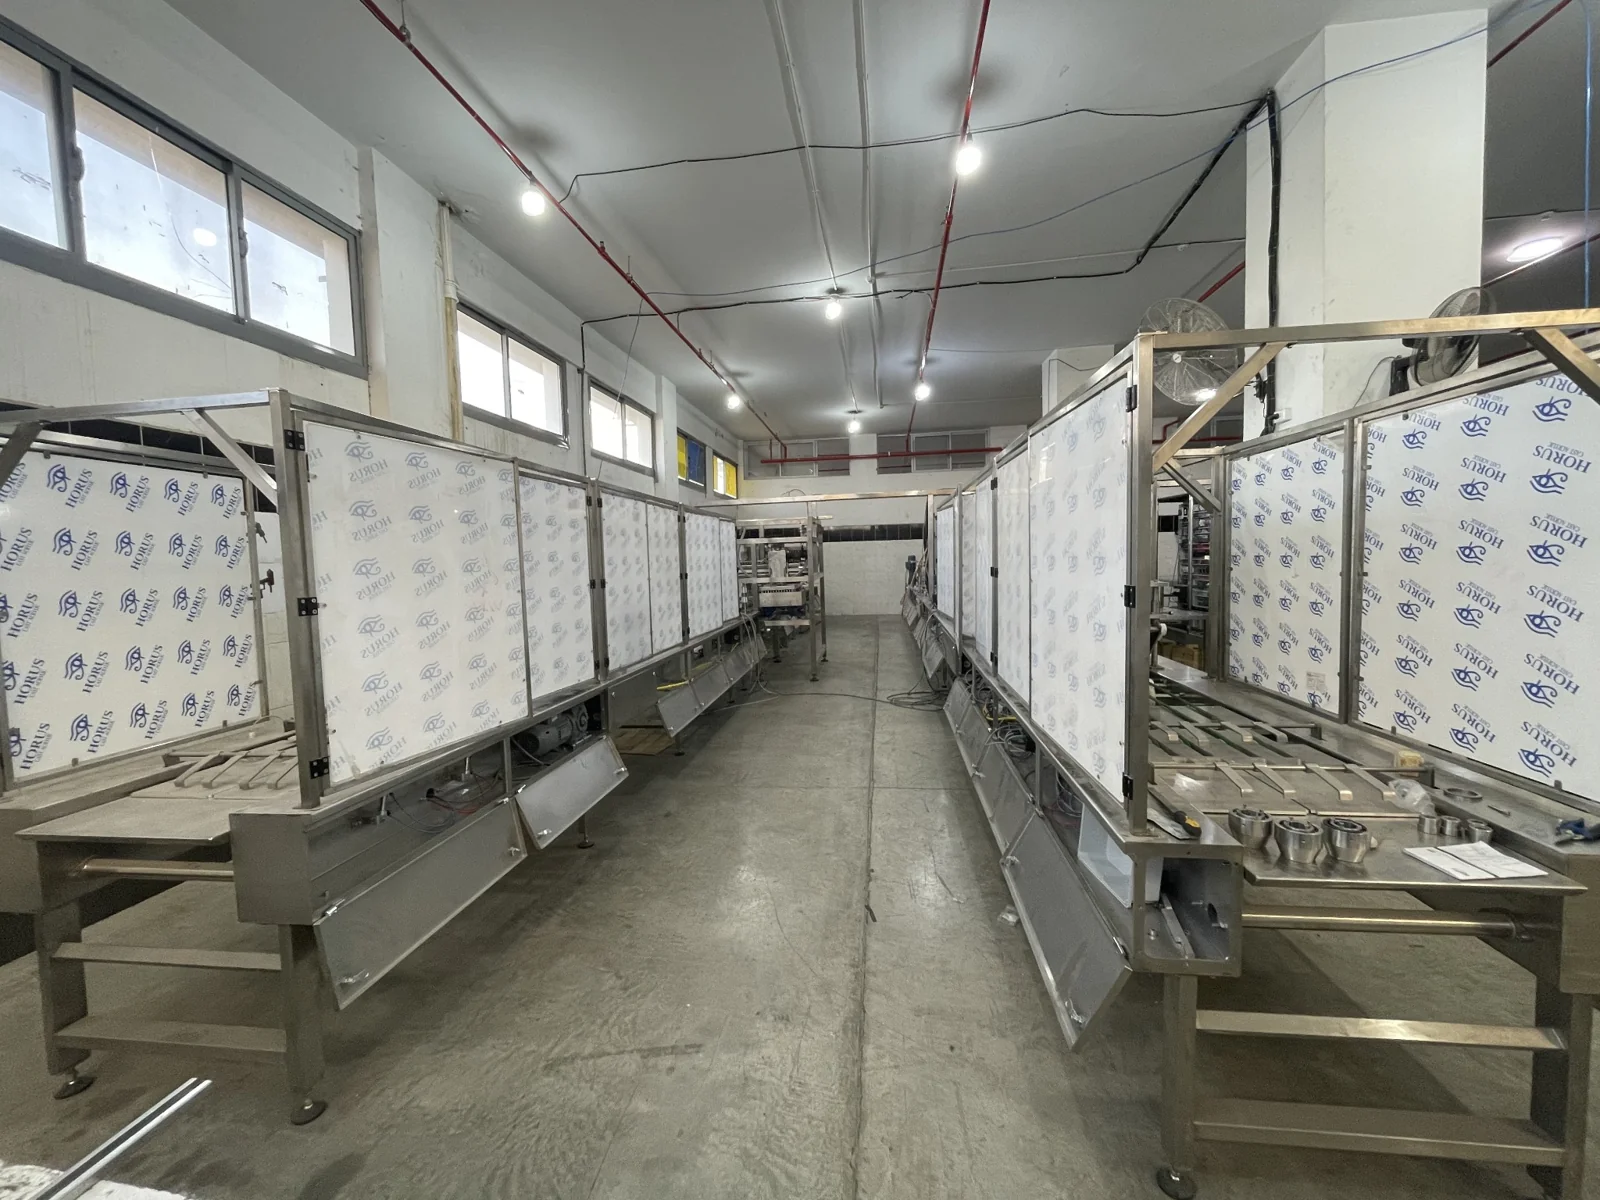
The requirement
Pick nuts and place them into product cavities while synchronizing handling with the conveyor.
PR-05 / KEMI PROJECTS
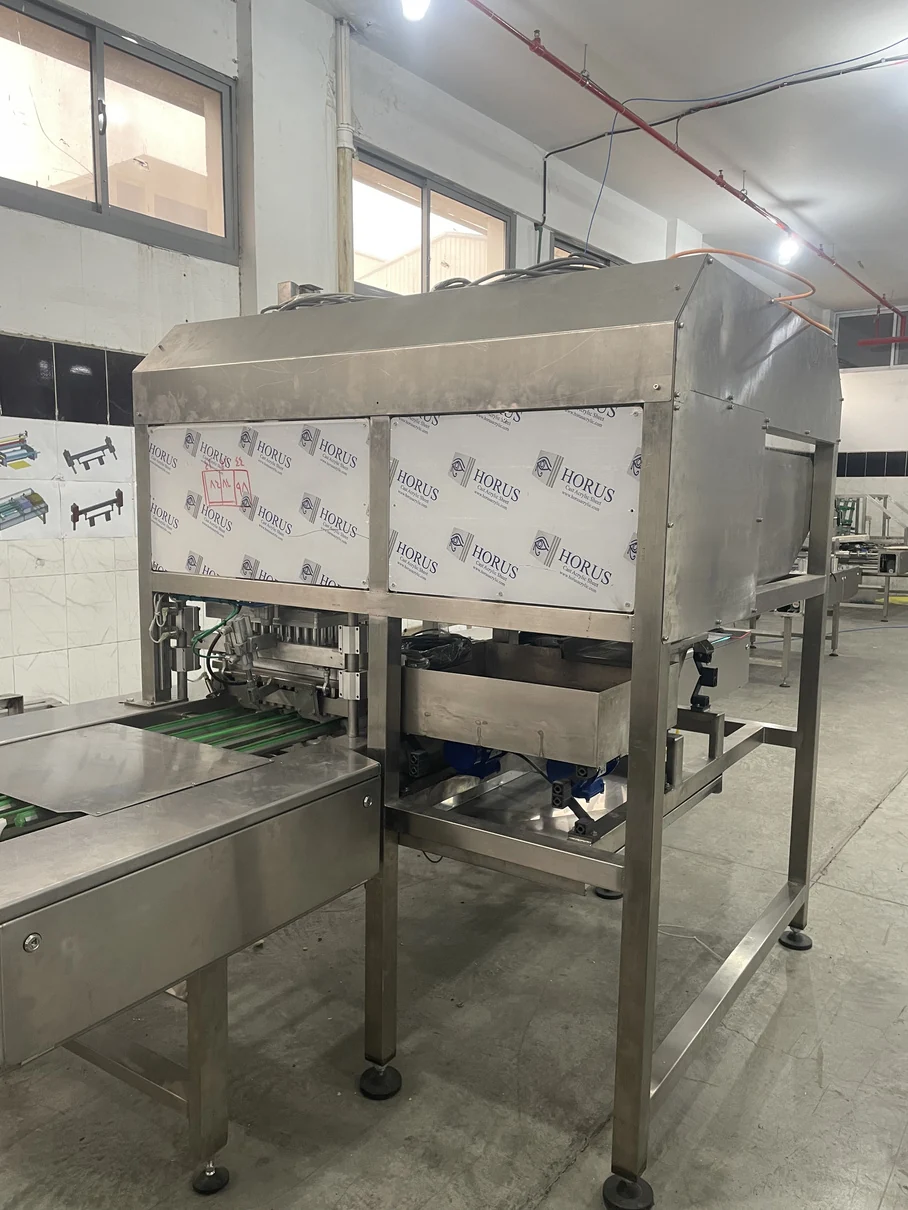
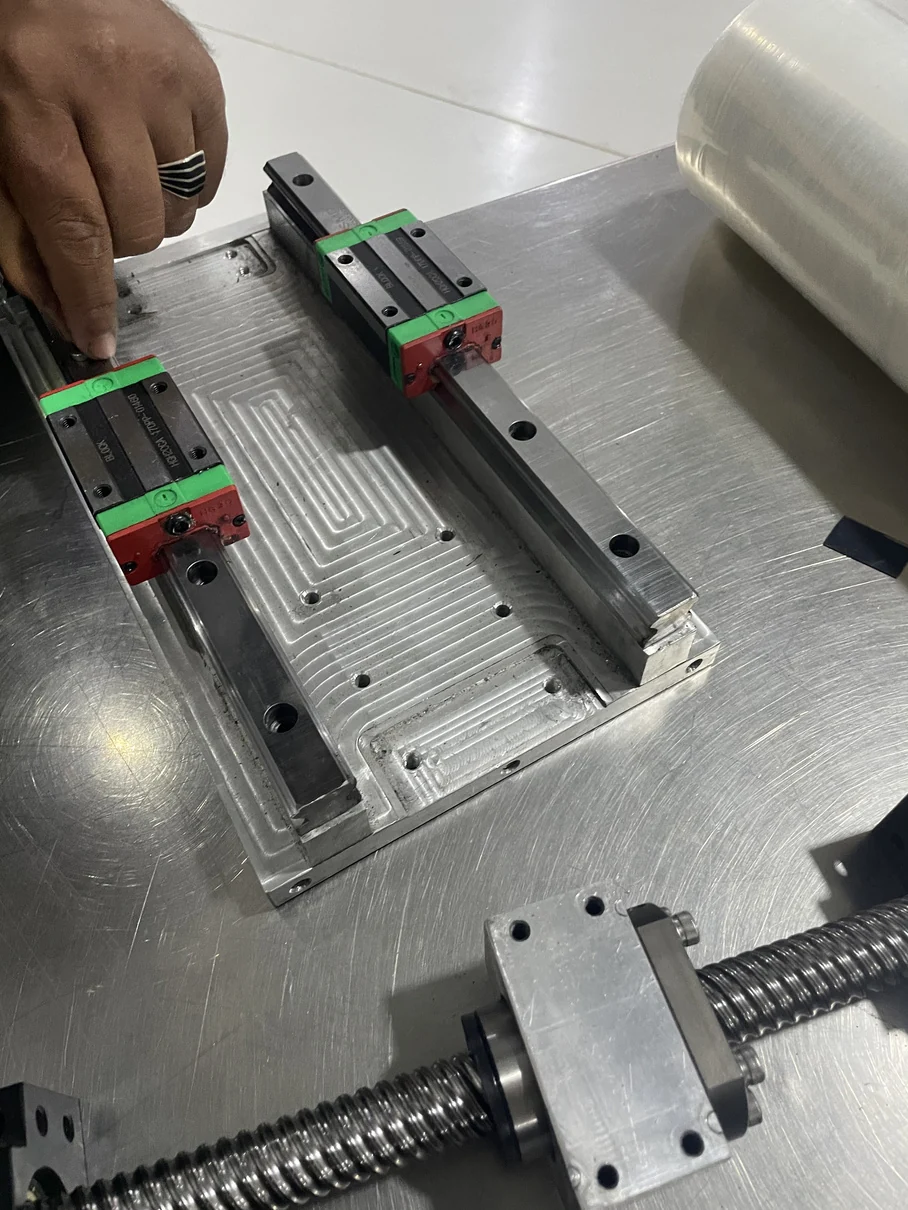
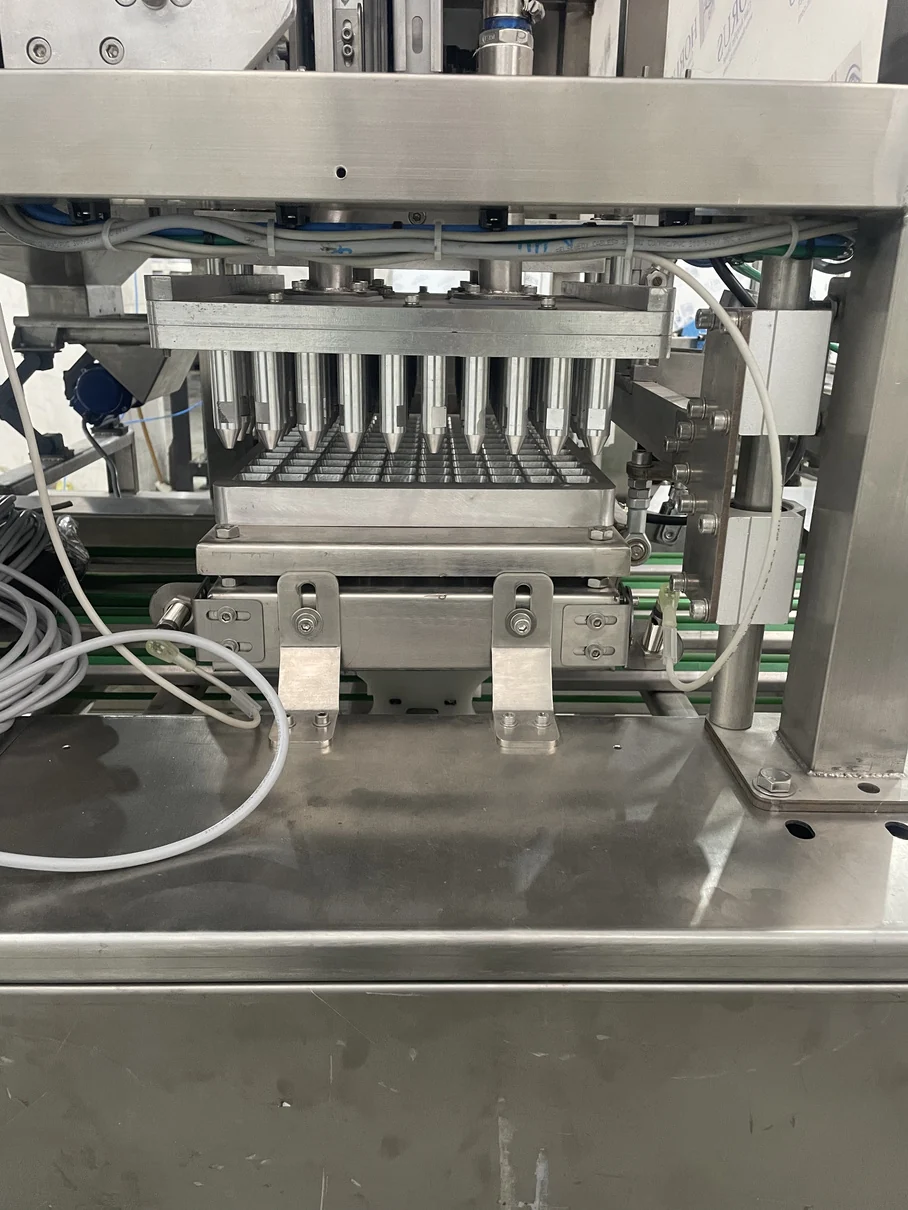
Design and manufacture of a two-axis Cartesian robot to pick nuts and place them into product cavities. Servo motion, vacuum pickup and sensors synchronize handling with the conveyor, within the available production-line space.
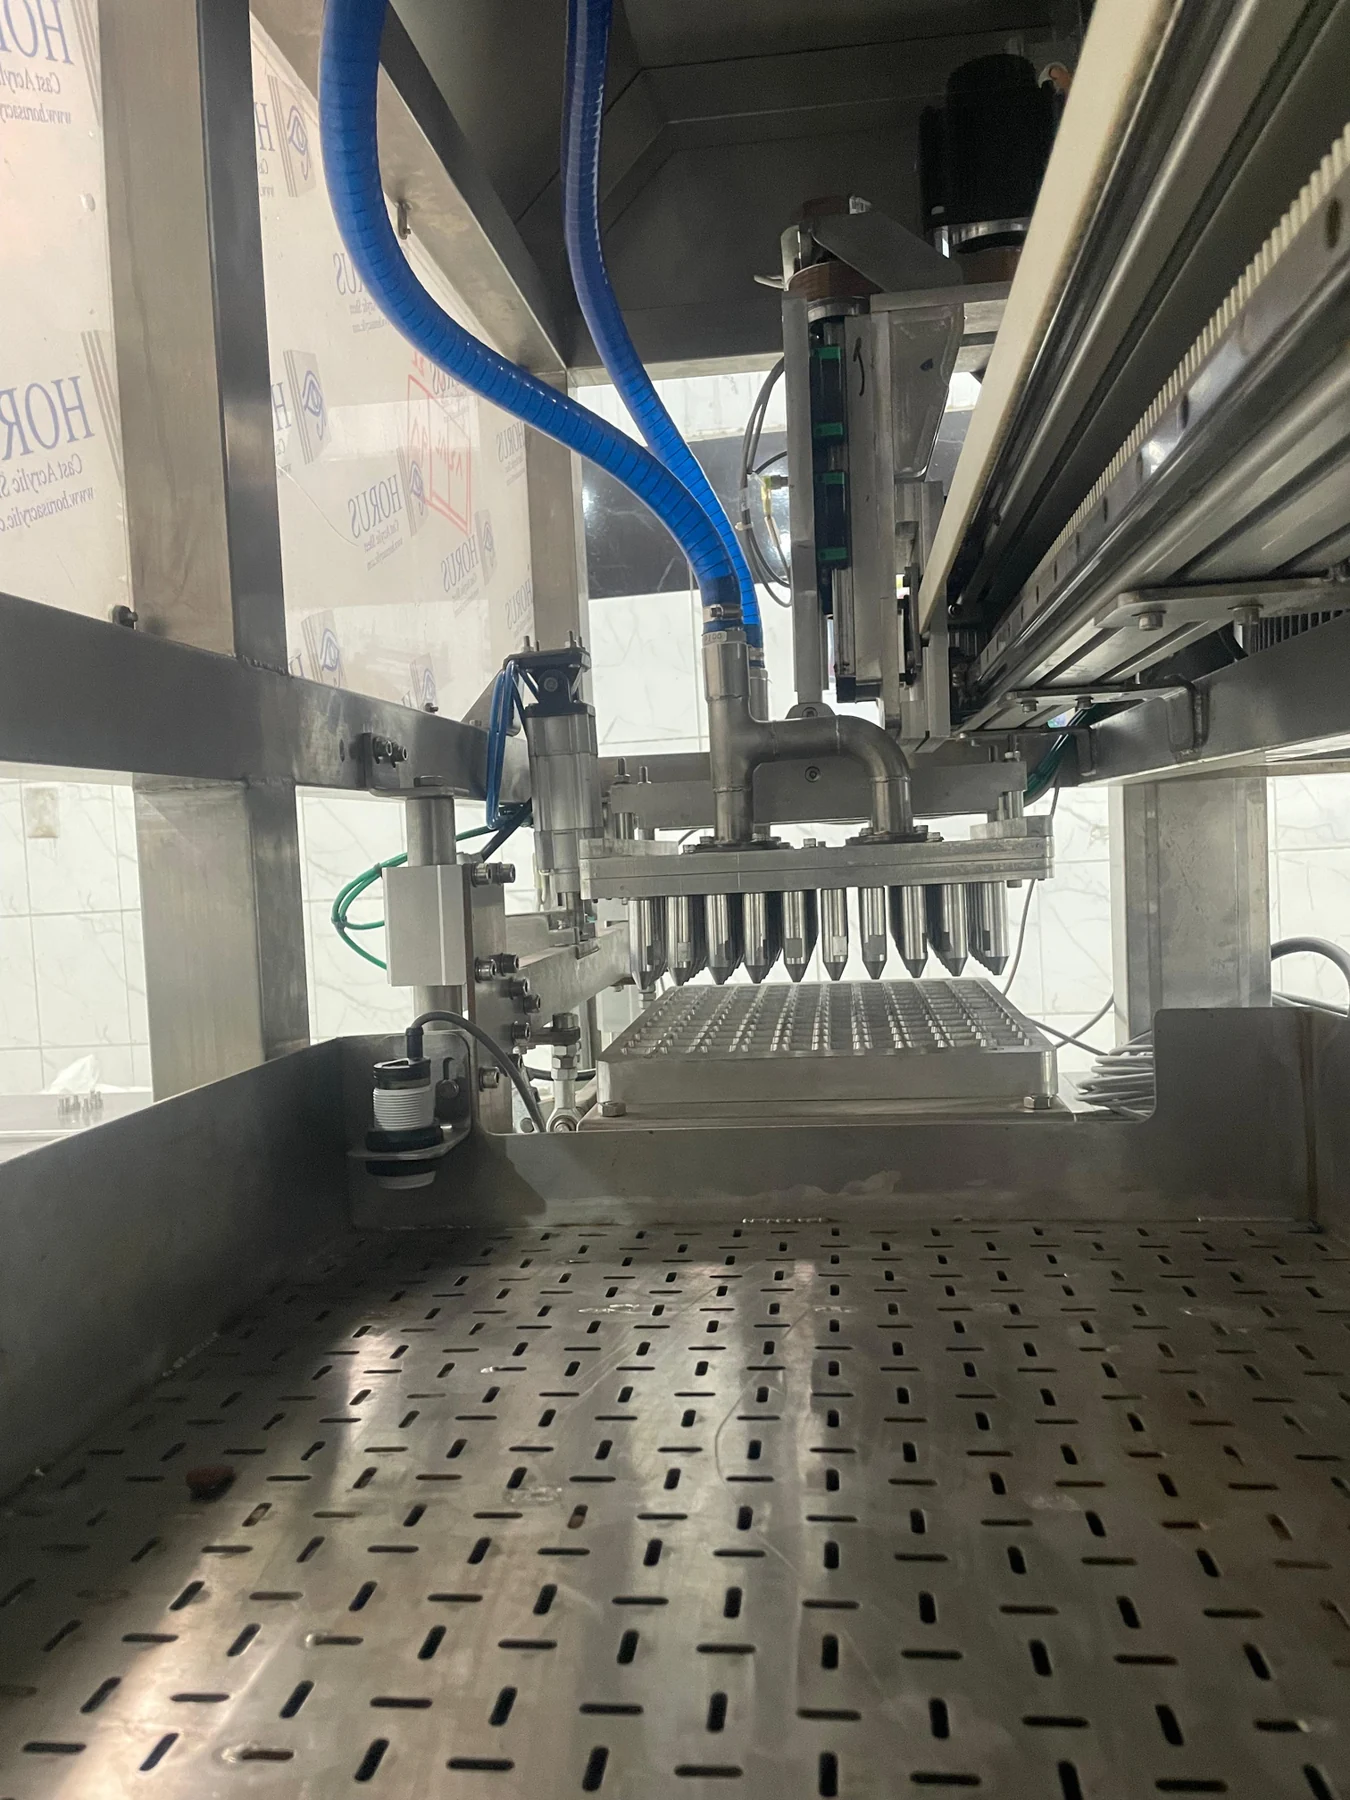
Pick nuts and place them into product cavities while synchronizing handling with the conveyor.
Design and manufacture of a two-axis Cartesian robot to pick nuts and place them into product cavities. Servo motion, vacuum pickup and sensors synchronize handling with the conveyor, within the available production-line space.
| Mechanism | Cartesian robot & vacuum pickup units |
|---|---|
| Motion | Servo motion, sensors & conveyor coordination |
| Application | Product pickup and placement within a production line |
DESIGN / BUILD / APPLICATION
Photographs and designs from KEMI projects.
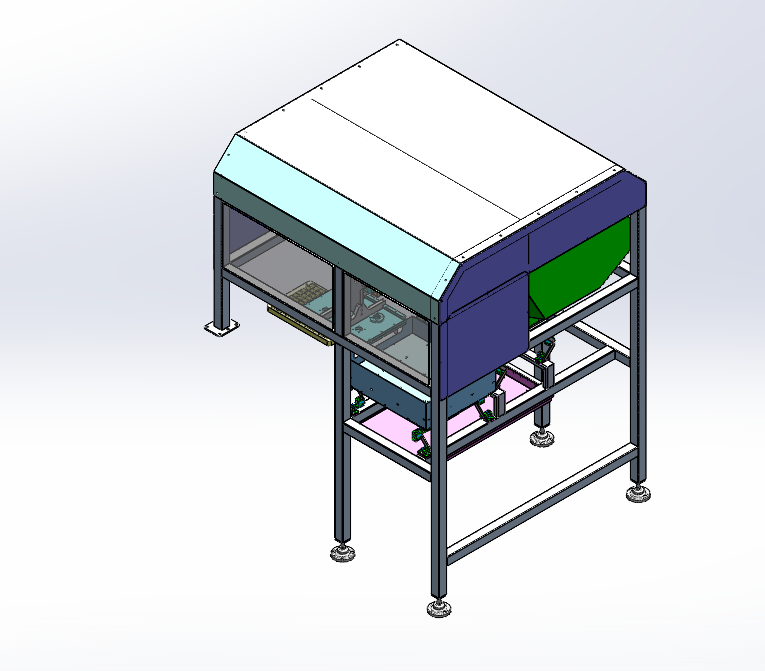
Start with your project requirements and define a configuration around your product, throughput and available space.
Request a quote